
Startup Self-Test
A power-on sequence that checks supported displays, speakers, controls, antennas, software, and stored configuration.
- Coverage varies by product
- A passed test is not full reception proof
- Failures need explicit indication
Radar-detector operating function matters because every alert depends on several active states. The device must start correctly, scan enabled bands, apply the selected sensitivity and filters, classify incoming patterns, combine direction or location context, and present the result through sound and display. A lit screen proves only one part of that chain.
Configuration also determines silence. A muted volume, stored GPS lockout, disabled band, city filter, stale database, lost satellite fix, failed rear antenna, overheated receiver, or broken audio link can suppress or reshape warnings. Each feature therefore needs an operating contract: starting state, input, decision, output, feedback, failure indication, and recovery.
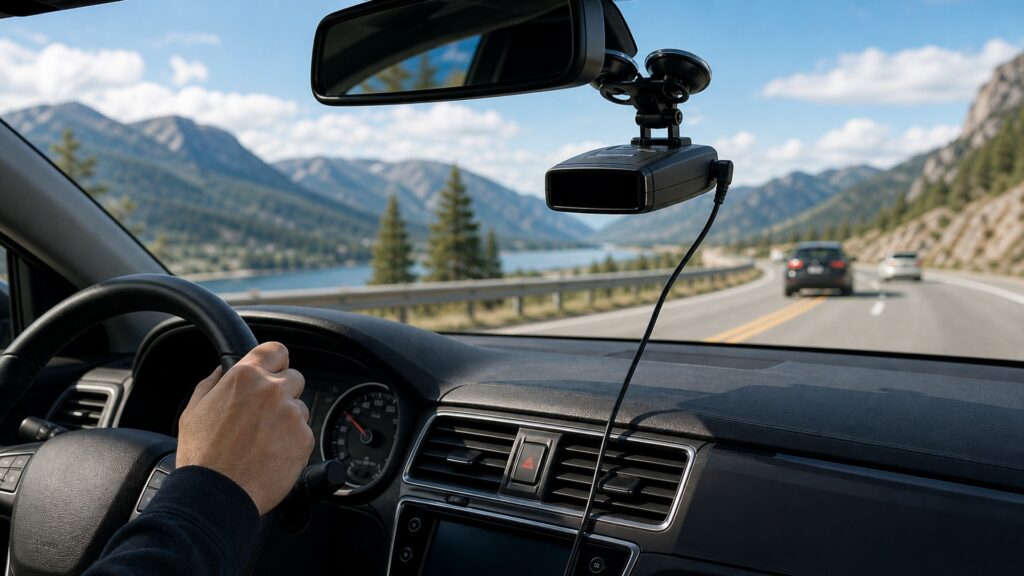
A dependable detector makes reception, filtering, suppression, output, and failure states distinguishable to the user.
Tip: Record the configured profile before testing; without that baseline, silence cannot be separated from intentional suppression.
These terms describe state changes that should be observable without guessing.
A power-on sequence that checks supported displays, speakers, controls, antennas, software, and stored configuration.
A profile that changes receiver gain, band response, filtering, or alert policy for environments such as highways or cities.
The progression of alert level or repetition as measured received energy changes.
A condition after which the device lowers or suppresses audible output while retaining specified visual or later escalation behavior.
A stored geographic and often frequency-related rule that suppresses recurring alerts near a known position.
The documented condition reached after lost power, GPS, antenna, phone, audio link, update, or fault clears.
Tip: Preserve exact mode, band, volume, location, and software information in any fault report.
The detector should expose its software state, band profile, volume, brightness, GPS condition, antenna availability, and any fault. Fast boot is useful only if missing sensors or reset settings are not concealed.
Startup establishes the baseline from which later alerts can be interpreted.
Scanning behavior follows regional configuration, selected bands, sensitivity mode, filters, and hardware channels. The interface should make disabled coverage obvious and preserve the user's chosen profile across ordinary restarts.
Scanning is a configured process, not a universal fixed capability.
For each supported alert type, define tone, voice, display label, arrows, strength ramp, persistence, and escalation. Conflicting sources or low-confidence classifications should not masquerade as precise identification.
Presentation succeeds when the driver can understand it briefly and calmly.
Manual mute, automatic volume reduction, quiet-speed behavior, band rejection, and GPS lockouts suppress different outputs. The detector should show which rule acted and allow safe review without creating silent unknown states.
Useful filtering reduces nuisance while preserving accountability for silence.
The device should identify unavailable inputs, retain safe settings, use documented fallback, and reconnect without duplicate or missing alerts. Updates and thermal faults also need clear progress, cancellation, and post-recovery checks.
Recovery is part of normal function because vehicle power and wireless links are not continuous.
No sound may mean no classified energy, manual mute, automatic suppression, a lockout, disabled coverage, failed input, low volume, broken integration, or powered-off hardware.
Visible mode, band, GPS, mute, and fault states let the user explain why presentation changed.
A local alert path can preserve essential feedback if a phone or receiver link fails.
No alert does not prove no measurement source exists nearby.
A startup self-test cannot reproduce every radio environment or laser geometry.
These myths treat buttons and quiet operation as proof of complete detection behavior.
It confirms selected output and internal checks, not windshield transmission, real antenna sensitivity, every enabled band, GPS accuracy, directional balance, database currency, or external interference. Use controlled observations to test the installed signal path.
Mute usually changes audible presentation for a current alert, while a location lockout suppresses future alerts under stored geographic and frequency conditions. Their scope, indicators, escalation, and reset behavior require separate tests.
Additional filtering can reduce nuisance, but it may also delay or suppress weak signals depending on product rules. Match mode to the documented environment and keep disabled or reduced coverage visible to the user.
The receiver may continue detecting while the chosen alert path disappears. Verify a local speaker or visible fallback, connection status, latency, and automatic recovery so a silent integration failure is not mistaken for quiet conditions.
Tip: Validate inputs, decision rules, output, and recovery separately.
These answers establish concrete operating checks for configuration, alerts, suppression, and recovery.
Check expected self-test indications, volume, brightness, selected profile, enabled bands, front and rear antenna status, GPS fix where used, database date, phone or audio connection, and any reset or fault message.
Use the same lawful route, detector location, known recurring sources, traffic period, and settings except the mode. Record alert timing, band, direction, persistence, and nuisance rate without turning the drive into a speed test.
Verify the saved coordinate and frequency scope, observe the suppression indicator on repeated passes, approach from different directions, check nearby distinct signals, and confirm the entry can be reviewed, corrected, or deleted safely.
The detector should expose lost connection and use its documented local sound or display fallback. After reconnection, verify alert latency, volume, duplicate messages, media restoration, and retention of mute and mode settings.
Confirm version and database dates, retained band and sensitivity profiles, volume, brightness, lockouts, GPS, antennas, local alerts, audio integration, startup, shutdown, faults, and recovery systematically on a documented acceptance route.
Radar-detector operating function matters because startup, scanning, classification, strength, direction, mute, filters, lockouts, databases, audio handoff, faults, and recovery can each change what the driver perceives.
Define those states before use and retest after updates or installation changes. A dependable detector makes both alerts and silence explainable without demanding attention from the driving task.
These explainers locate every state in the signal chain and show how to preserve its baseline over time.
Map each operating state to antenna capture, frequency analysis, classification, context, and output.
Verify the legal, glass, orientation, power, heat, and interference conditions supporting operation.
Preserve settings, firmware, databases, mounts, cables, and a repeatable route baseline.
Choose a retailer
Prices checked regularly. We may earn a commission at no cost to you.